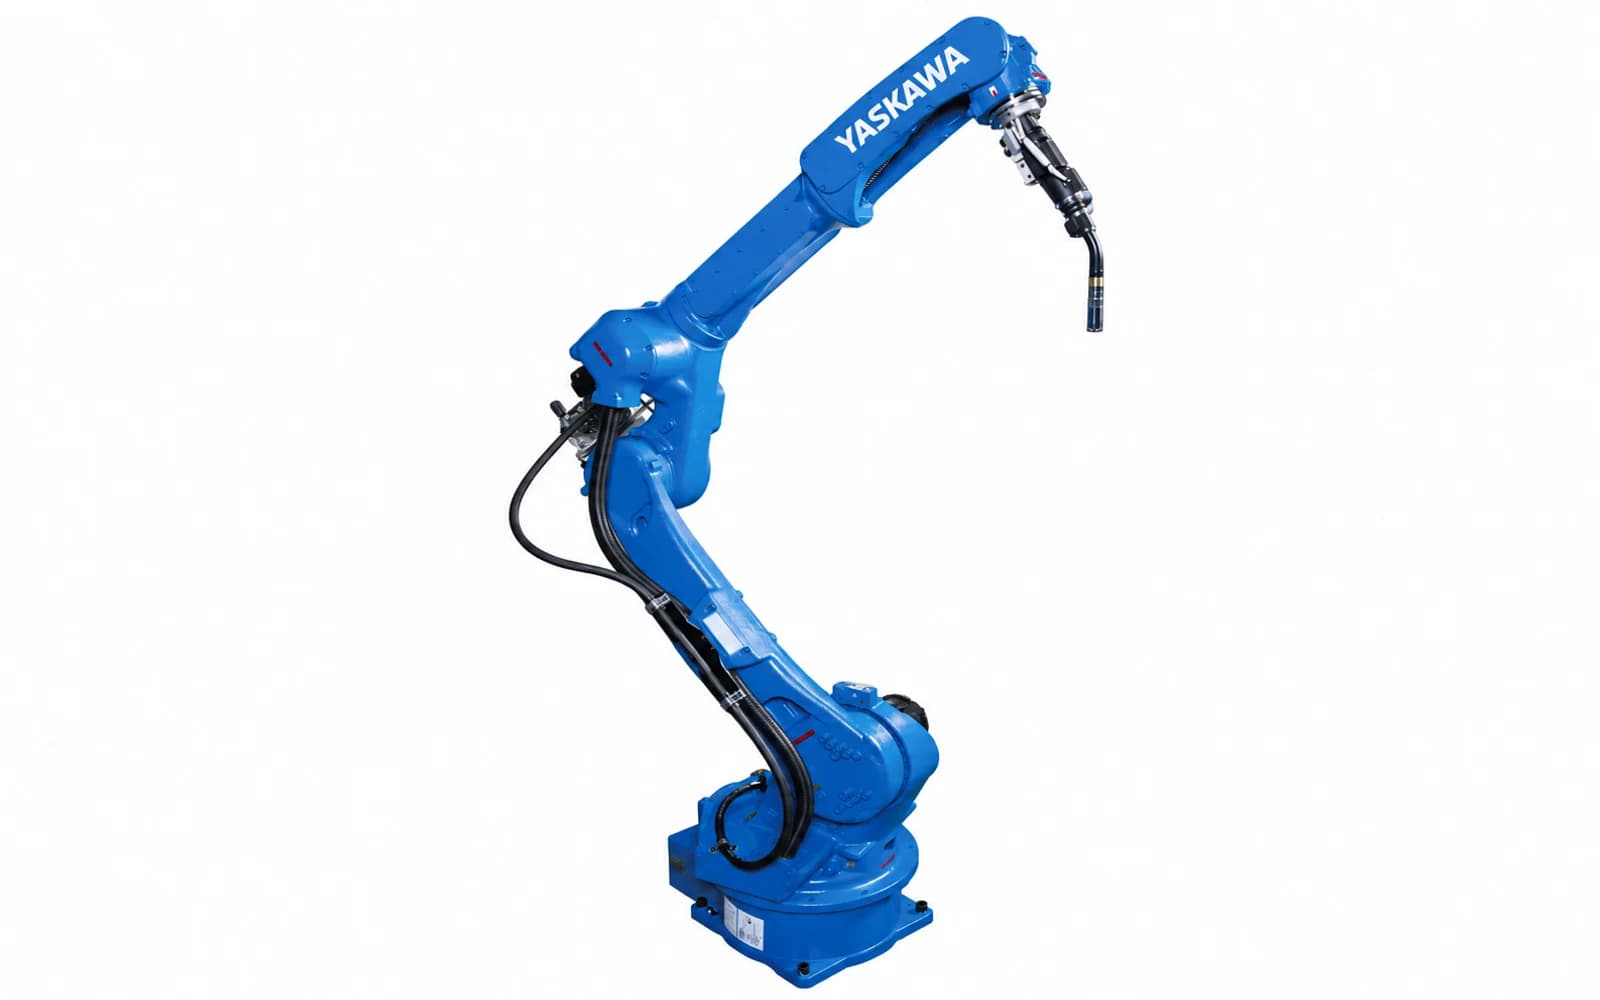
Yaskawa
Yaskawa MOTOMAN AR2010
Yaskawa MOTOMAN AR2010 is a six-axis arc-welding robot with a 2010 mm working range and YRC1000 controller. Its supplied load entry separates the 12 kg maximum payload from a 9 kg U-axis rating; those values describe different mounting positions.
- Maximum payload
- 12 kg (9 kg on U-axis)
- Maximum working range
- 2010 mm
- Controlled axes
- 6
Torch access and welding configuration
Use the 260 kg robot weight for the installation load case and ±0.03 mm repeatability for the stated motion characteristic. Locate feeder equipment, torch services and the fixture before checking the full arm sweep; do not add U-axis and wrist ratings together.
A welding robot supplies motion; the weld is produced by the complete process package. Match the torch, feeder, power source, wire and shielding gas to the joint and material. Check the torch angle and distance at every seam, including clamps, corners and the path between joints. Fixture repeatability and incoming fit-up determine how consistently the robot meets the joint. Where variation requires sensing, specify whether the task is initial seam location or correction during welding. These are different functions with different hardware, software and commissioning requirements.
Application focus
- Arc welding
Specifications and selection notes
Maximum payload
Include the complete moving assembly. Check center of gravity and inertia as well as mass; a nominal load is not a rating for every offset or motion.
Maximum working range
Check the required tool position and orientation with the fixture and clamps in place. The geometric limit alone does not establish usable access.
Controlled axes
Check the required motion with the loaded assembly, limits and services. Specify indexing or coordinated movement and the selected drive arrangement.
Repeatability
Keep the stated measurement and conditions. Repeatability, absolute accuracy and finished-part quality are different characteristics.
Define what you need supplied
Robot and controller
Select reach and tool load, then identify the controller and installed welding functions.
Welding equipment
Configure the torch, source, feeder, cooling and consumables for the joint.
Fixture and cell
Add workholding, positioners, extraction, safeguards and the required loading arrangement.
Match the equipment to your installation
Allow for welding screens, fume capture, hot-part handling and maintenance, not only the robot sweep. Route torch services and the welding return path deliberately. Confirm the welder interface, external axes, cleaning station and restart sequence with the offered controller. Test the agreed joints and inspection method on representative parts before fixing the production settings.
| Selection factor | Information to specify |
|---|---|
| Joint and material | Drawings, thickness, weld size, incoming gap and the specified inspection method. |
| Torch and fixture | Tool mass, neck geometry, clamp locations, access angle and changeover method. |
| Process and sensing | Power source, wire, gas, seam location/tracking and controller interfaces. |
| Production sequence | Loading, clamping, weld order, cooling, inspection and unloading as a complete cycle. |
From the part to the equipment package
- 01Define joints and fit-up
- 02Locate and clamp the part
- 03Check torch paths and motion
- 04Set the welding package
- 05Test welds and the full cycle
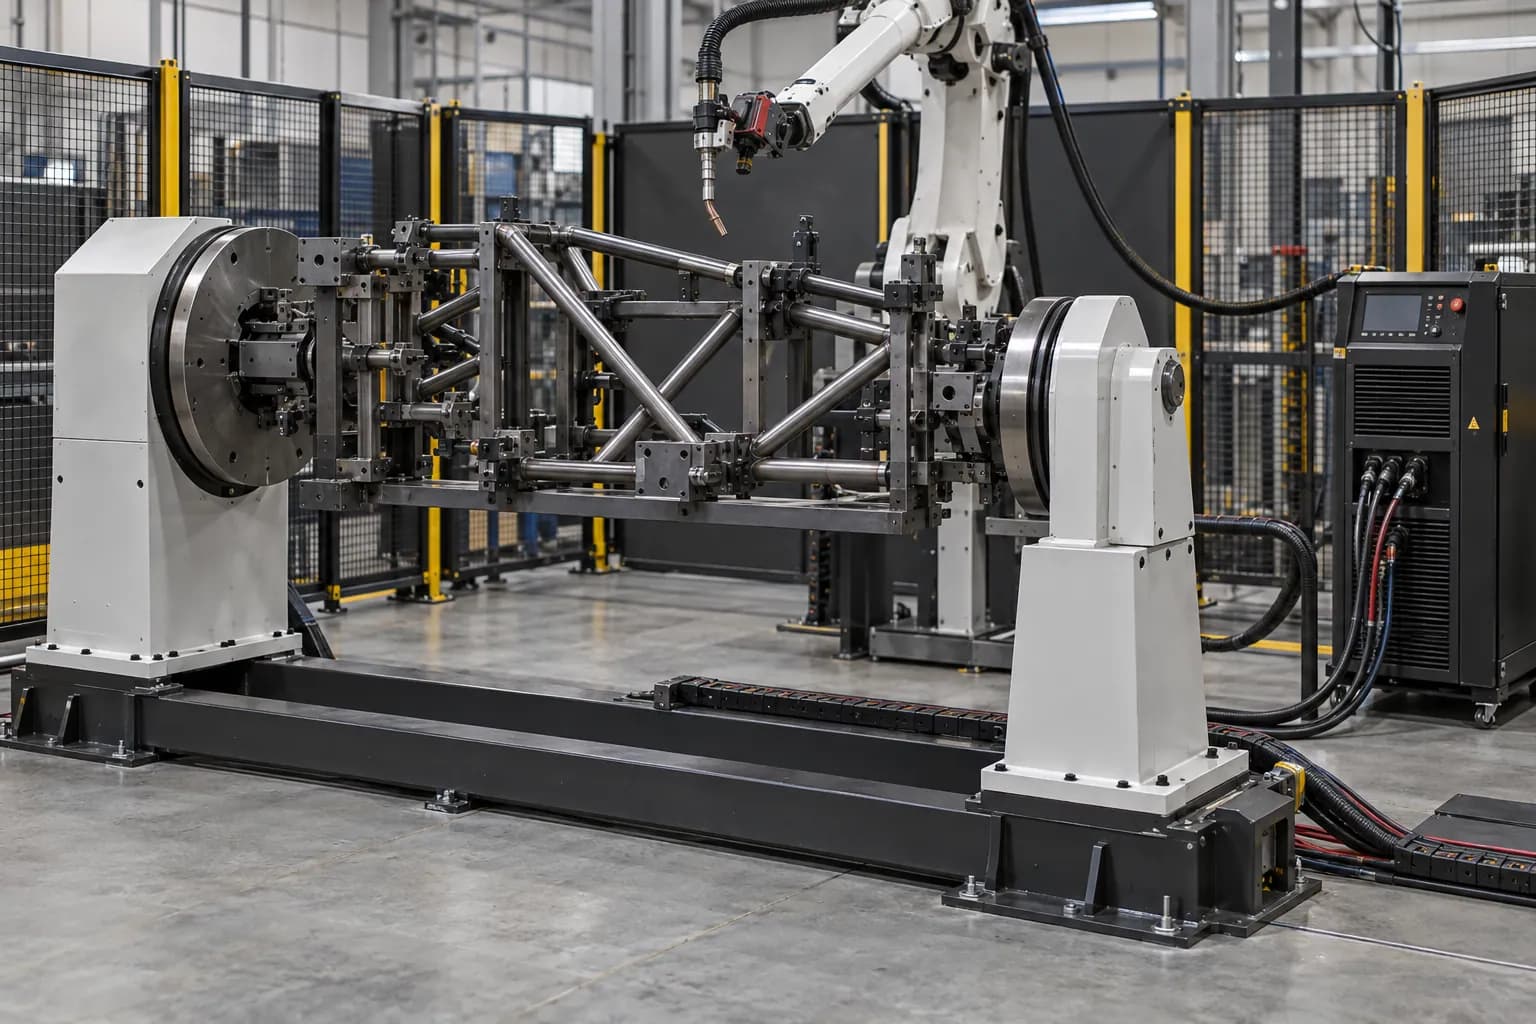
Tooling, interfaces and service access

Product and ordering questions
01What are the applications of Yaskawa MOTOMAN AR2010?+
Yaskawa MOTOMAN AR2010 is a six-axis arc-welding robot with a 2010 mm working range and YRC1000 controller. Its supplied load entry separates the 12 kg maximum payload from a 9 kg U-axis rating; those values describe different mounting positions.
02Does robot repeatability establish weld quality?+
Robot repeatability describes a motion characteristic, not the finished weld. Joint preparation, fixture location, wire, gas, process settings, heat sequence and part variation also matter. Agree the sample parts, weld inspection and acceptance criteria for the actual application rather than translating a robot tolerance into a weld-quality promise.
03What should I consider when choosing Yaskawa MOTOMAN AR2010?+
Use the 260 kg robot weight for the installation load case and ±0.03 mm repeatability for the stated motion characteristic. Locate feeder equipment, torch services and the fixture before checking the full arm sweep; do not add U-axis and wrist ratings together.
04What should the equipment package include?+
Identify the selected equipment and separate the following packages: robot and controller, welding equipment, fixture and cell. State which accessories, controls, installation, programming and commissioning are included. This makes equipment-only and integrated proposals comparable without assuming identical supply scope.
05How can I request a quotation for Yaskawa MOTOMAN AR2010?+
Send the required model or arrangement, quantity and destination, plus drawings, thickness, weld size, incoming gap and the specified inspection method; tool mass, neck geometry, clamp locations, access angle and changeover method. Add photographs or drawings and identify existing equipment. TubeFrame can then discuss model sourcing, configuration and partner-supported integration as separately defined work packages.
Specify your next equipment package
Send the model or configuration, drawings, quantity and destination. We will discuss equipment sourcing, technical interfaces and any integration work required for your application.