Robotic Welding
Configure robot, power source, torch, feeder, fixture, positioner, sensing and safety around the weld and workpiece.
Review application ↗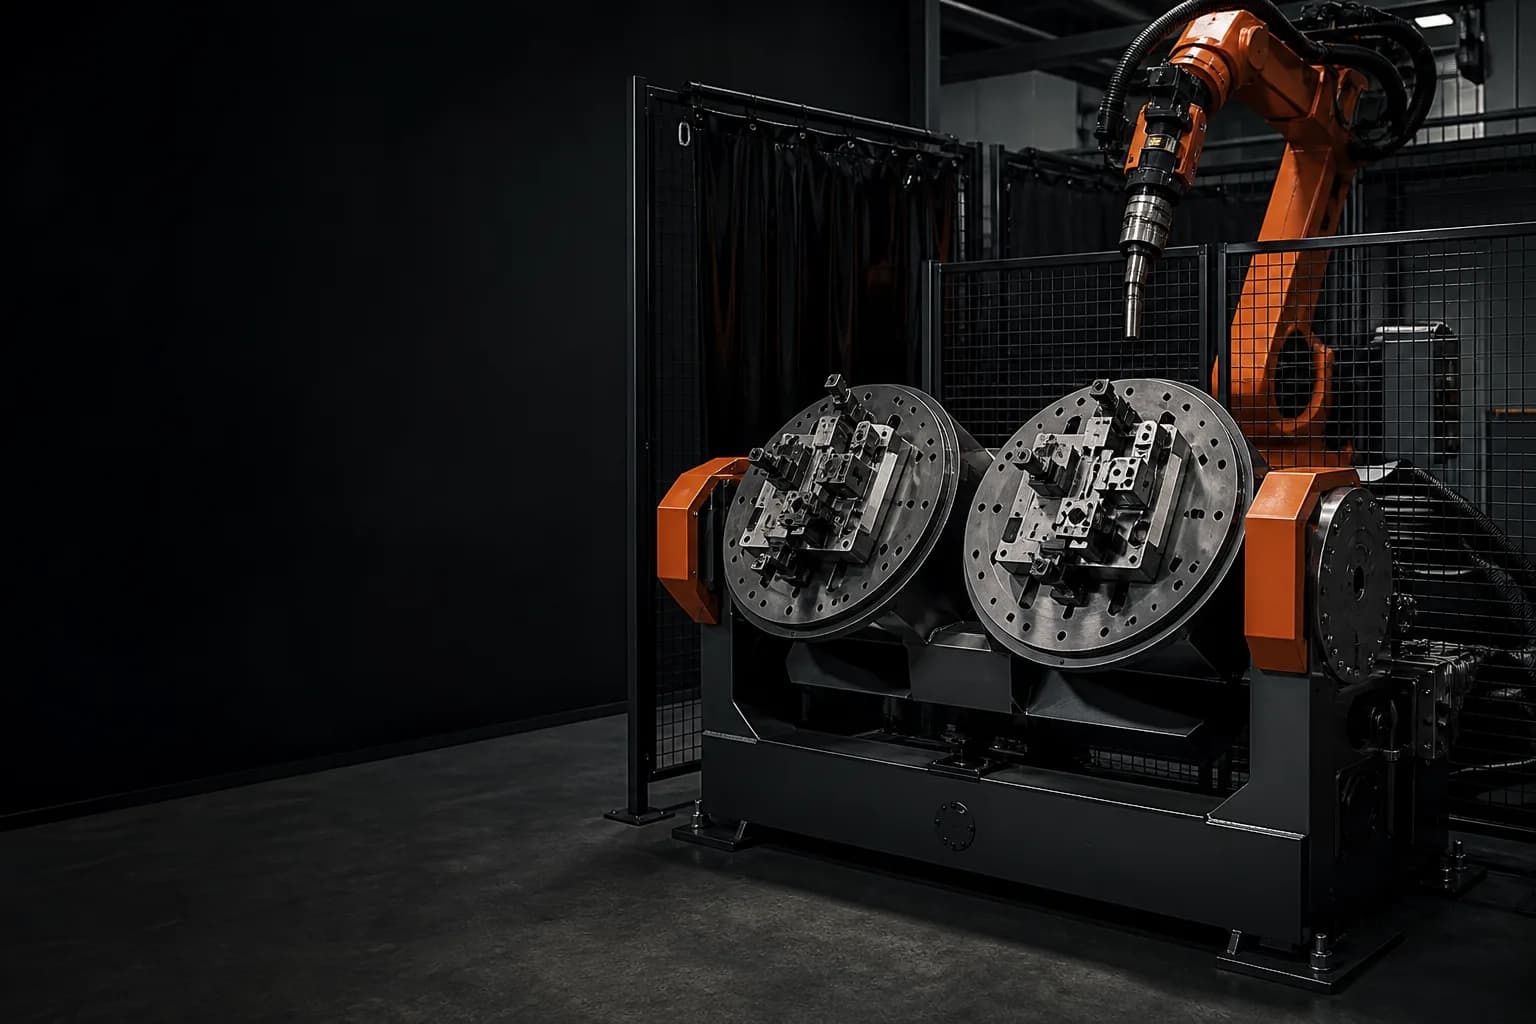
Review the KBR-Z500C for longer weldments that need supported rotation, adjustable fixture span and coordinated robot access.
Long frames can meet total load limits while overstressing supports or blocking robot access because weight distribution and sweep were not modeled.
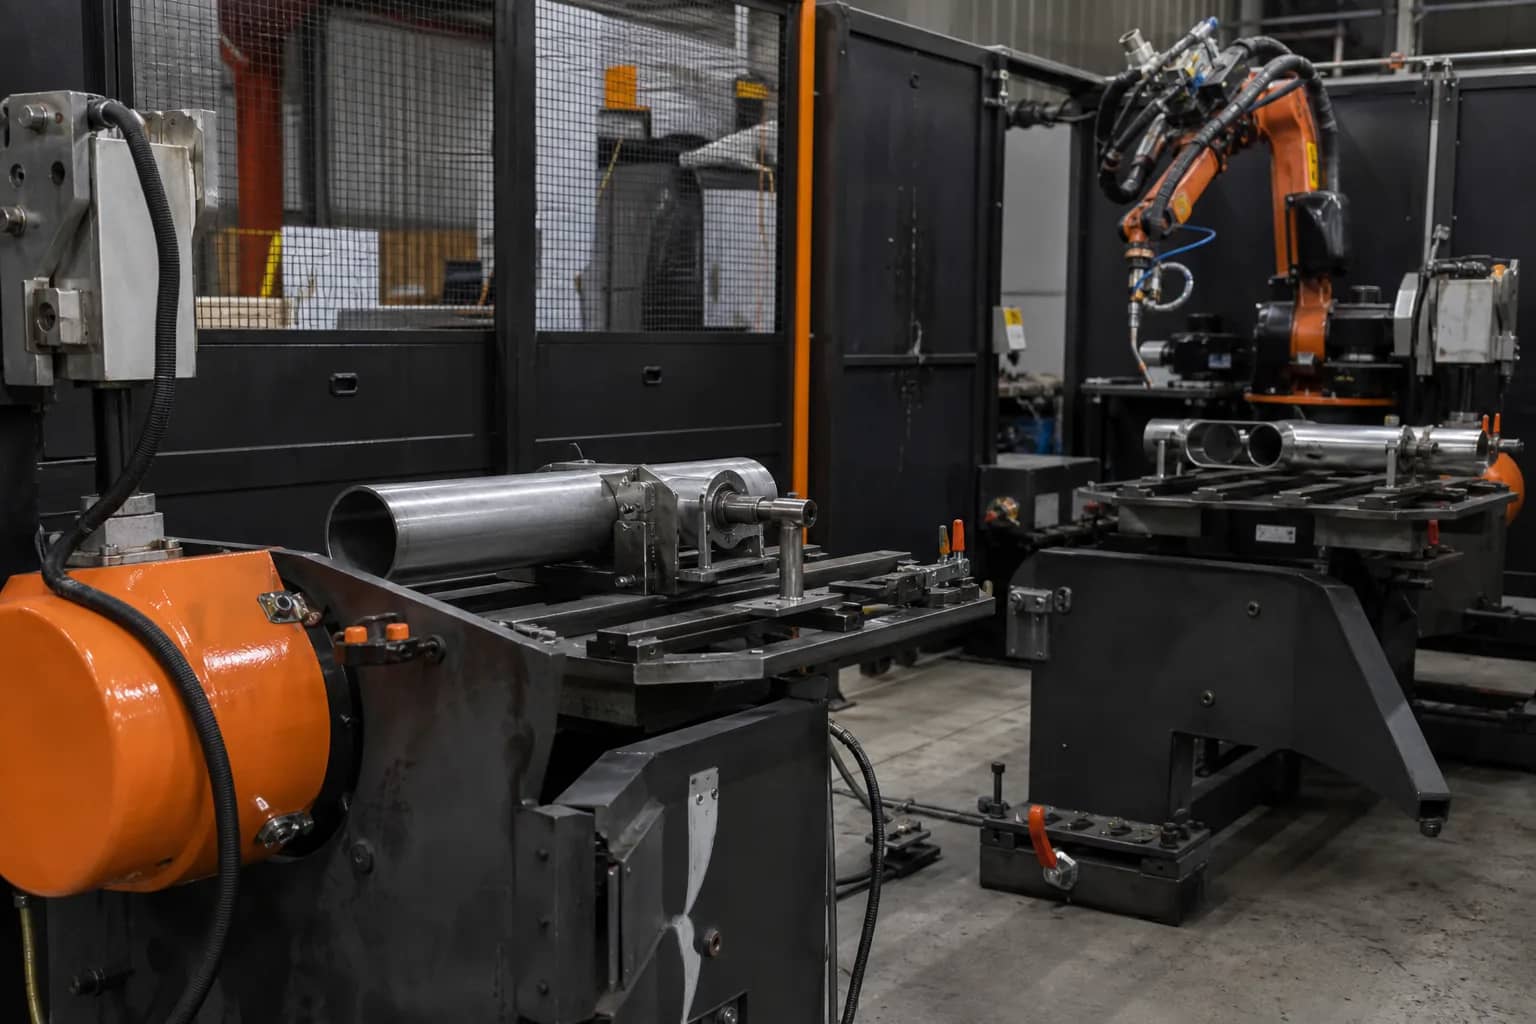
Payload, reach and tool access are checked against the actual workpiece and production target.
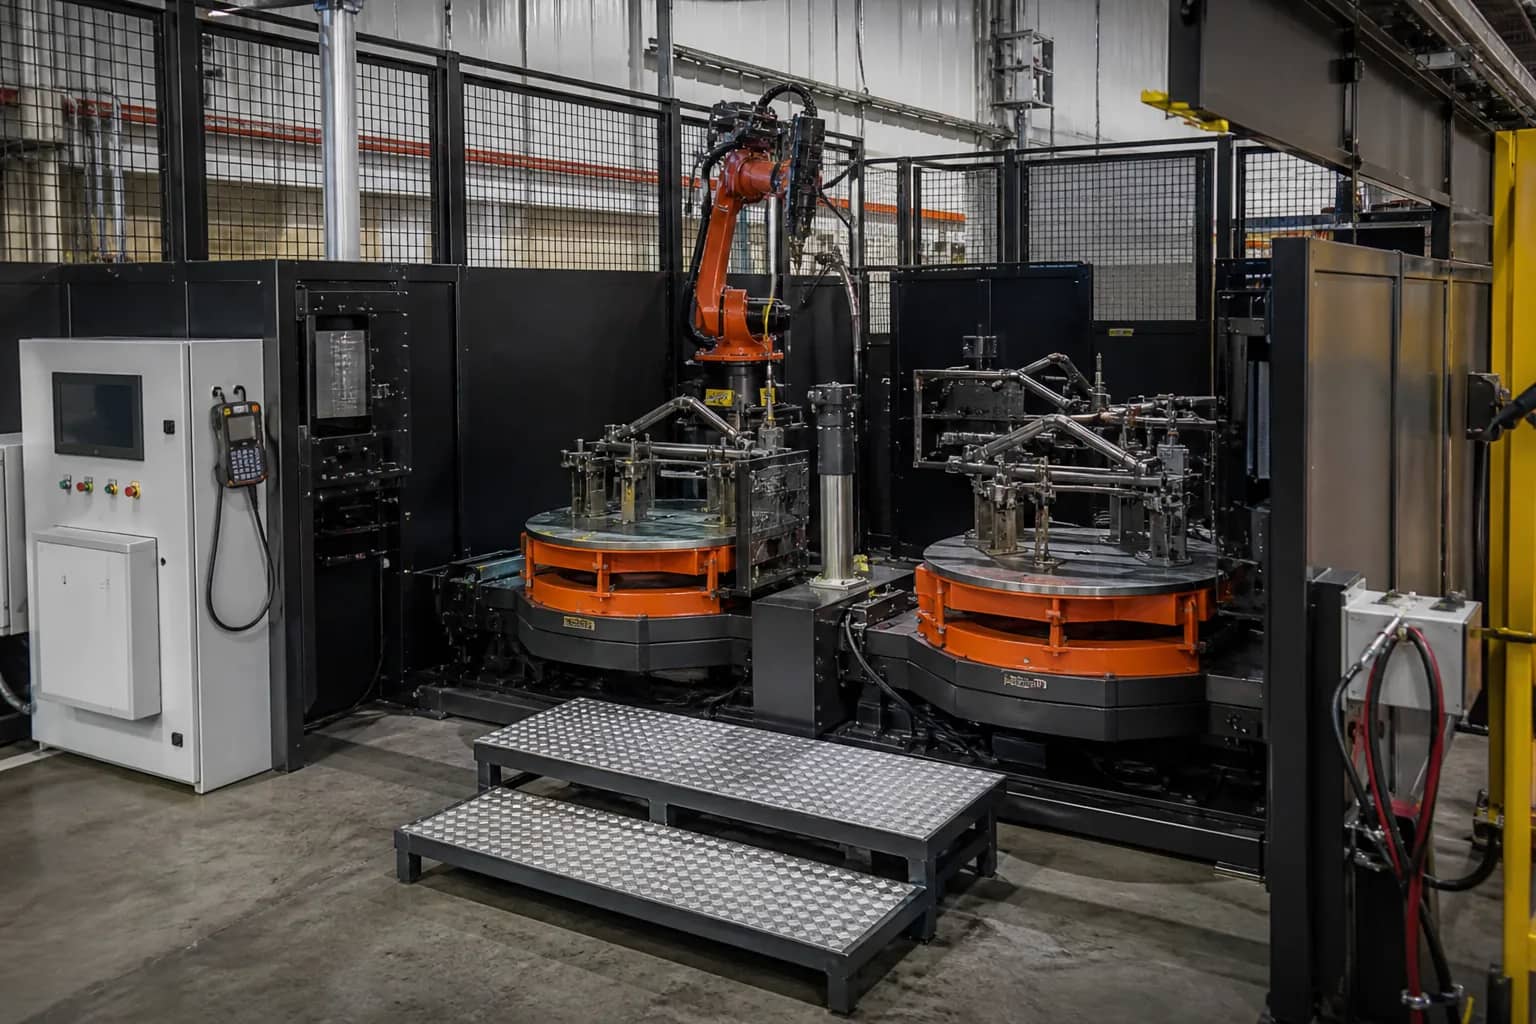
Tooling, workholding, controls, safety and access determine whether the platform becomes productive equipment.
A positioning configuration to evaluate by fixture support, rotating load, weld orientation and robot control interfaces. Select the robot, controller and accessories to match your workpiece, process and installation requirements.
Start with the part, process and required result.
Check mass, moments, access, cycle and interfaces.
Define the installation requirements and acceptance tests.
Catalog-based technical path: compare the robot, controller and positioner as one cell decision in the Yaskawa welding cell selection guide →
Configure robot, power source, torch, feeder, fixture, positioner, sensing and safety around the weld and workpiece.
Review application ↗Include the workpiece, gripper, adapters, cables and process tooling—not payload alone.
Prove tool angle, fixture clearance, singularity margin and service access in the actual layout.
Connect motion time, process dwell, sensing and recovery logic to a credible output target.
Define fieldbus, machine handshakes, utilities, guarding and ownership before release.
Send the workpiece, total moving mass including tooling, center of gravity, reach and tool-access requirement, process, target cycle, environment, layout, interfaces, destination and preferred commercial route.
Ask for current stock and delivery options for the selected robot and controller. Include your tooling, software, destination and installation requirements so the quotation covers the configuration you need.
Workpiece geometry, total moving mass, center of gravity, reach and access, process, cycle, environment, interfaces, safety and destination determine the released configuration.
Yes. The reviewed scope may include controller, EOAT, process equipment, workholding, sensing, guarding and adjacent equipment when the required interfaces and responsibilities are defined.
Send drawings or clear photos, material and dimensions, workpiece and tooling mass, process target, cycle or output, layout, utilities, destination and any preferred control or brand standard.
Send the long-part and fixture dimensions to compare supported-positioning options.